
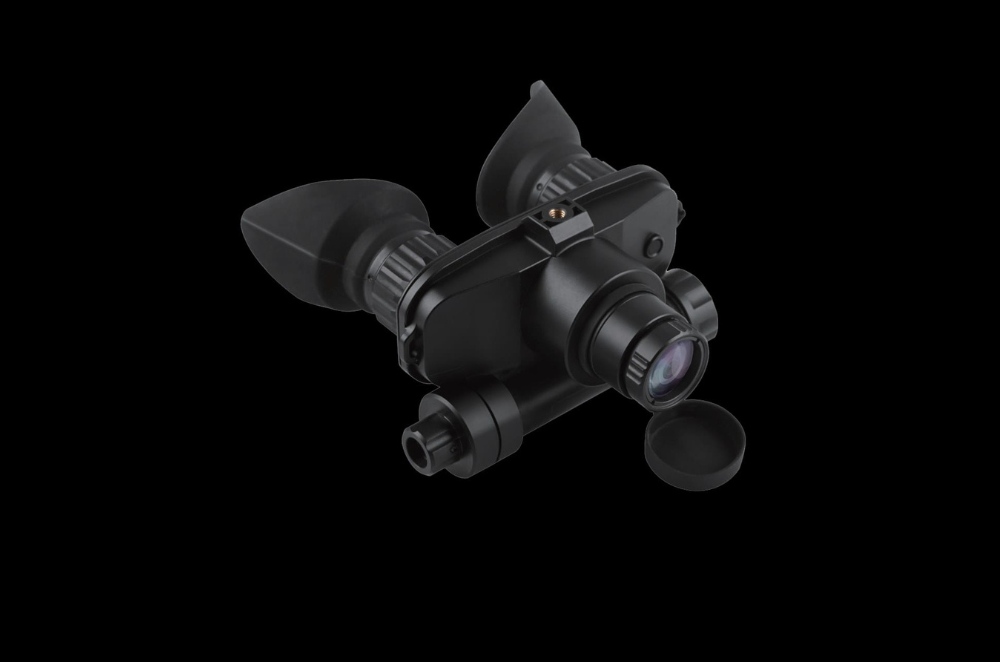
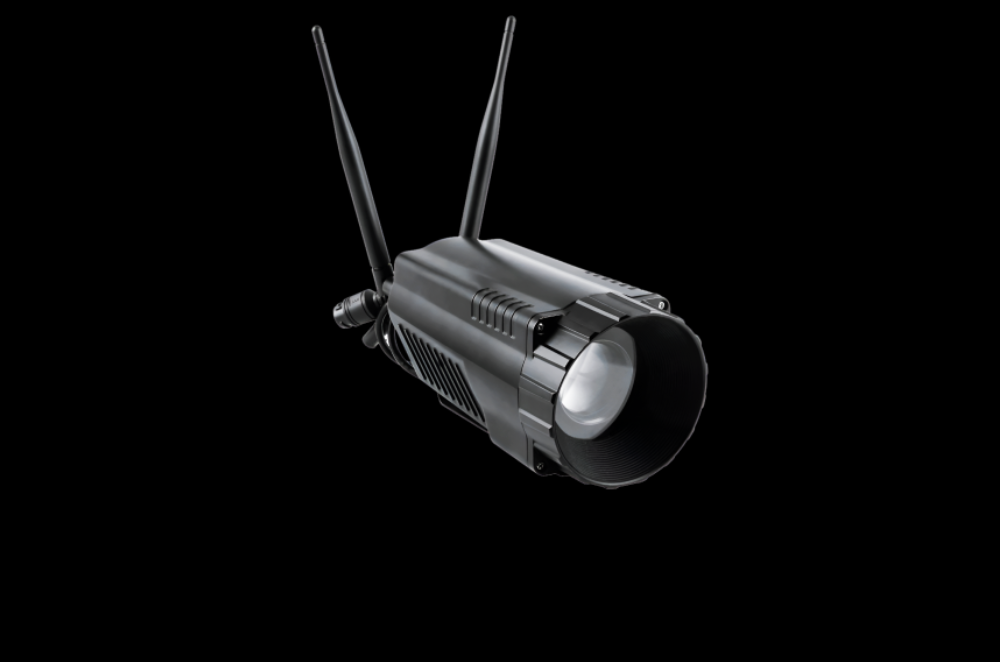
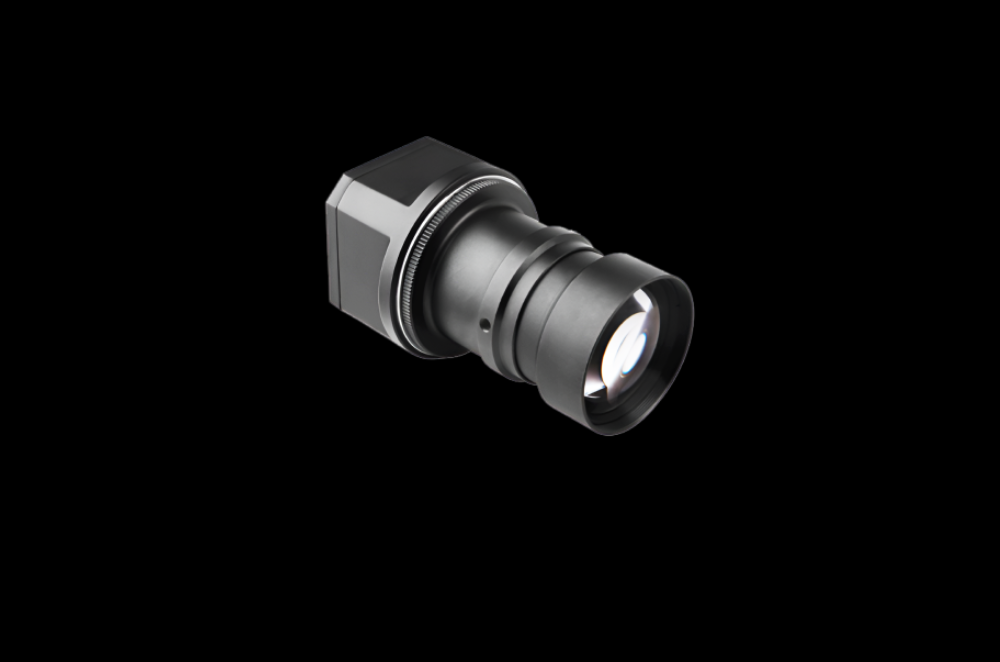
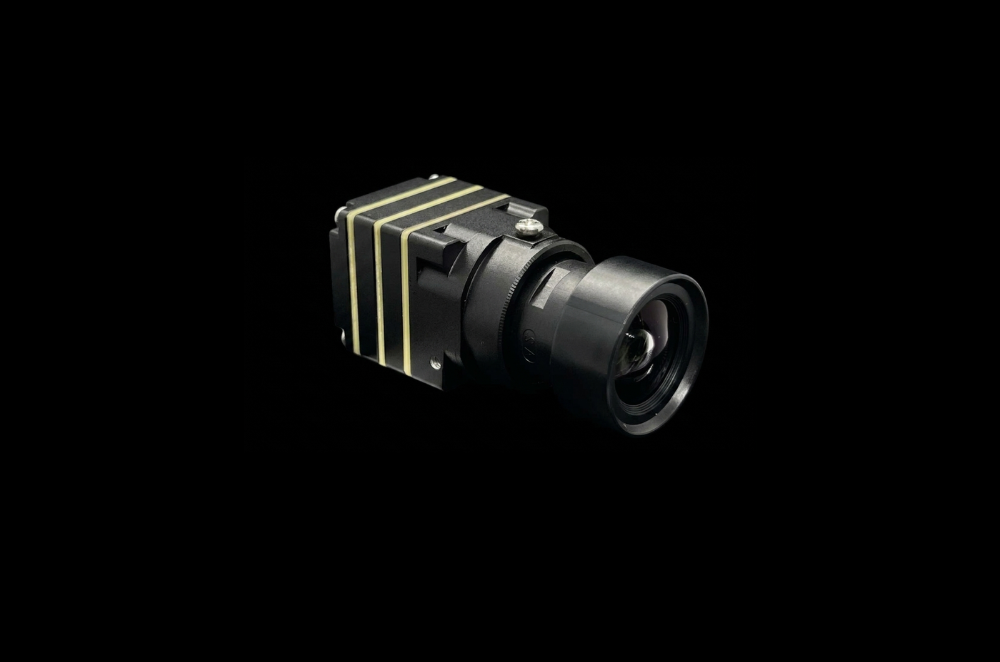
XUW4008C-B Deep-Water Binocular Stereo Camera
0.001 lux full-color binocular stereo camera with 500 m titanium housing for AUV/UUV/ROV navigation.
XUW4008C-B System Detail
What It Is
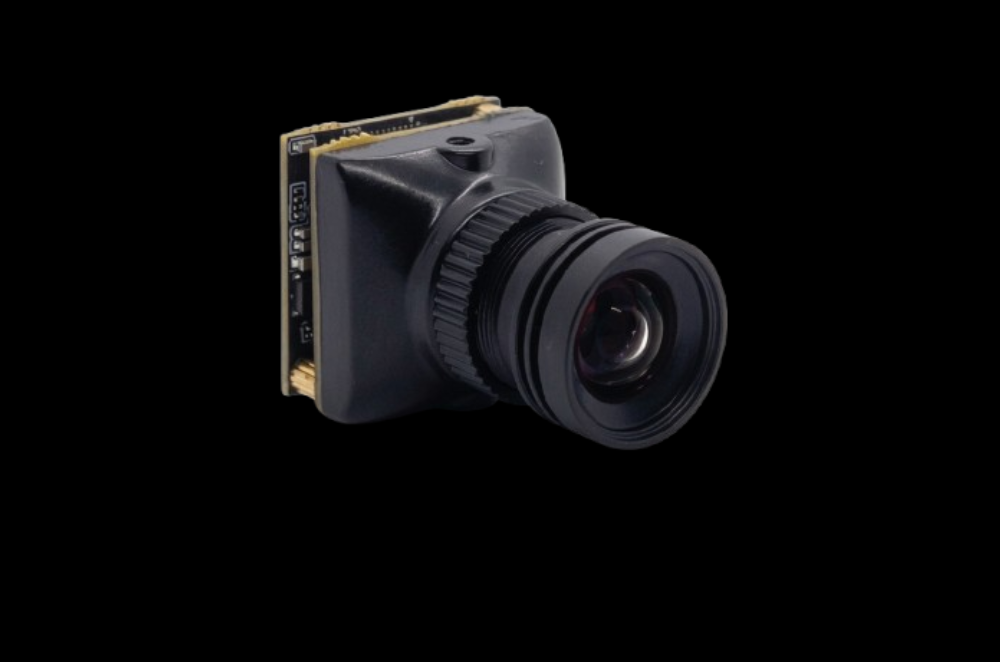
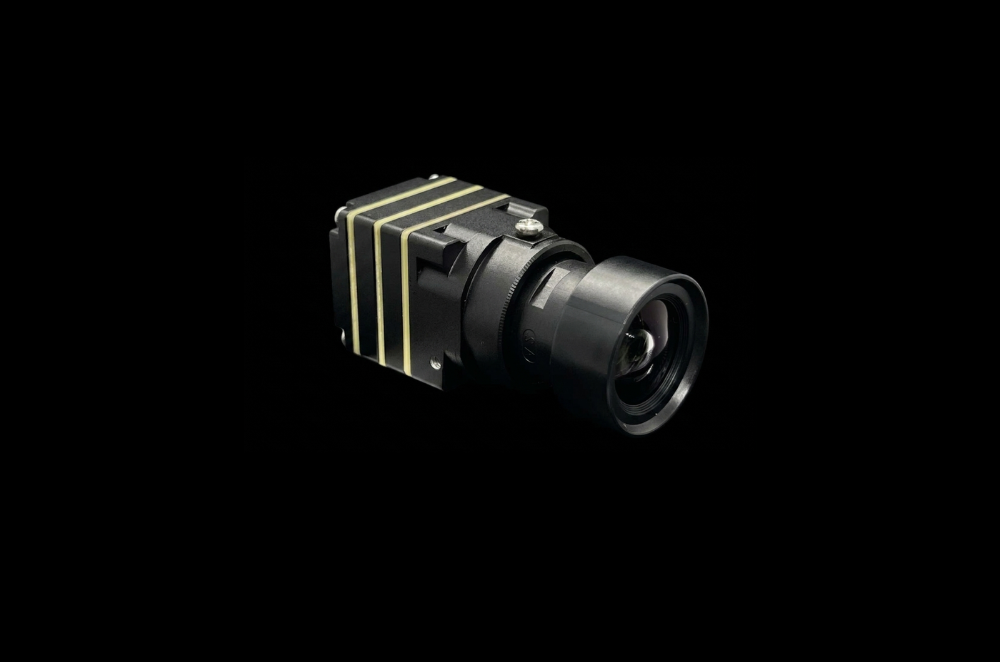
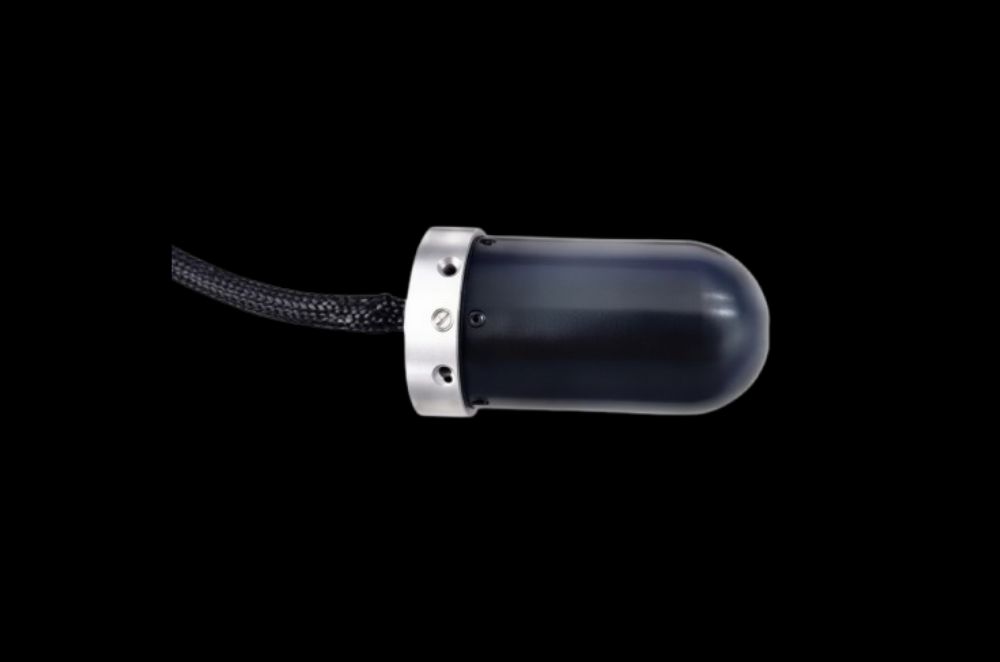
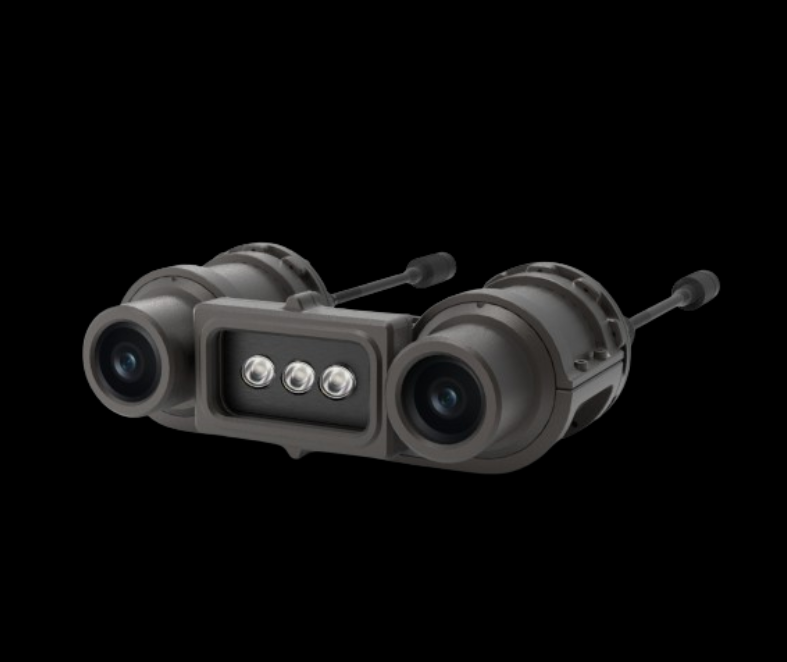
The XUW4008C-B is a deep-water binocular stereo camera built around dual CMOS image sensors, housed in titanium alloy and sapphire glass for underwater navigation and inspection aboard AUV, UUV, and ROV platforms.
Performance
The camera is rated to 500 m depth, resolves 1920 × 1440 video at 25 fps down to 0.001 lux without supplemental lighting, and covers a 170° horizontal field of view across its two optical channels.
Key Technical Features
- Dual-channel stereo imaging for depth perception and 3D modeling
- ONVIF Profile-compliant RTSP streaming in H.264 or H.265
- PWM-dimmable integrated white-light illumination with autofocus
- Single waterproof MCBH8MSS connector combining DC power and 100Base-TX Ethernet
Platform Compatibility
The dual-channel design and network video interface suit small-to-medium AUV and ROV payload bays where onboard stereo processing or 3D reconstruction is required alongside general subsea inspection duties.
Dual-Channel Stereo Imaging
Two synchronized optical channels capture the same underwater scene from offset viewpoints to support depth perception. The stereo configuration enables 3D modeling, obstacle avoidance, and precision navigation for AUV, UUV, and ROV platforms.
Ultra-Low-Light Color Sensing
A CMOS image sensor resolves full-color imagery in near-total darkness without relying on supplemental lighting. Integrated PWM-dimmable white-light illumination extends usable visibility further when ambient light is insufficient.
Deep-Water Titanium Housing
A titanium-alloy shell with a sapphire-glass front window seals both optical channels for sustained deep-water deployment. The safety-factor-rated pressure housing and corrosion-resistant construction withstand demanding subsea conditions.
IP Network Video Integration
A single waterproof connector carries both DC power and 100Base-TX Ethernet to a network video interface. ONVIF/RTSP streaming in H.264 or H.265 lets the camera integrate directly into standard IP-based vehicle control and recording systems.
Our technical team provides pre-sales support for system integration planning, field testing, and deployment assessment.
Contact Technical TeamFull Technical Specifications
| Parameter | Specification |
|---|---|
| GENERAL | |
| Model Number | XUW4008C-B |
| Product Series | XUW4008 Series |
| Product Type | Binocular Stereo Underwater Camera |
| OPTICAL | |
| Sensor Type | CMOS (EO/Super Low Light) — 1.1" CIS |
| Sensor Size | 1.1" |
| Resolution | 1920 × 1440 |
| Color Mode | Full-Time Color |
| FOV Horizontal | 170° |
| PERFORMANCE | |
| Min. Illumination | 0.001 lux @ 25 fps, IRE50, SNR ≥ 30 dB |
| Frame Rate | 25 fps |
| Dynamic Range | 72 dB / 100 dB (WDR On) |
| Shutter Type | Rolling Shutter |
| Shutter Speed Range | 10 μs – 40 ms (Adaptive) |
| MECHANICAL | |
| Weight | 4.78 kg |
| Weight in Water | 3.5 kg |
| Housing Material | Titanium Alloy, Sapphire Glass Window |
| ELECTRICAL | |
| Operating Voltage | 12 V DC ± 3 V |
| Input Voltage Range | 9–15 V DC |
| Power Consumption | 2.4 W Normal / 3.6 W Peak (Autofocus) |
| ENVIRONMENTAL | |
| Operating Temperature | −25 °C to +70 °C |
| Storage Temperature | −40 °C to +85 °C |
| Pressure Rating | 500 m @ Safety Factor 1.5 |
| INTERFACE | |
| Output Format | H.264 / H.265 |
| Interface Type | 100Base-TX Ethernet |
| Connector Type | MCBH8MSS (8-Pin Waterproof) |
| Streaming Protocol | ONVIF / RTSP |
| Internal Storage | 32 GB |
Designed for the Field
Underwater Robotic Vehicle Integration
The XUW4008C-B is built to serve as a stereo vision payload for AUV, UUV, and ROV platforms operating at deep-water pressure.
Underwater Stereo Perception
Dual optical channels give subsea vehicles the depth information needed for obstacle avoidance and 3D scene reconstruction.
IP Network Video Integration
Systems integrators connect the camera into existing vehicle control and recording software over standard Ethernet and ONVIF/RTSP.
Underwater Robotic Vehicle Integration
AUV, UUV, and ROV platforms need compact vision payloads that can withstand full-ocean-depth pressure without adding excessive mass to the vehicle's buoyancy budget. The XUW4008C-B's titanium-alloy, sapphire-glass housing is built for exactly this kind of continuous subsea deployment. Its depth rating and safety factor give integrators margin for real-world dive profiles, while its air and water weight figures make ballast calculations straightforward. A single waterproof connector delivers power over the same standard cable run used for data.
- Depth Rating: 500 m @ Safety Factor 1.5
- Weight in Air: 4.78 kg
- Weight in Water: 3.5 kg
- Operating Voltage: 12 V DC ± 3 V
Underwater Stereo Perception
Navigating and inspecting underwater environments demands imagery that stays usable across the wide range of natural lighting subsea conditions produce. The XUW4008C-B's dual optical channels capture the same scene from two viewpoints to recover depth information a single lens cannot. Full-time color rendering and a wide horizontal field of view keep obstacles and terrain features visible without stepping the vehicle's speed down. Wide dynamic range and an adaptive shutter hold detail in both bright and shadowed areas of the same frame.
- Resolution: 1920 × 1440
- Frame Rate: 25 fps
- Horizontal FOV: 170°
- Minimum Illumination: 0.001 lux
IP Network Video Integration
Vehicle control systems typically expect vision payloads to behave like standard network devices rather than proprietary hardware. The XUW4008C-B streams over a conventional Ethernet interface using the same ONVIF and RTSP protocols already supported by most vehicle control and recording software. Onboard storage buffers footage locally when a live network link isn't available, and H.264/H.265 encoding keeps bandwidth manageable over long tethered or acoustic-modem links. This lets the camera drop into an existing IP video pipeline with minimal custom integration work.
- Network Interface: 100Base-TX Ethernet
- Streaming Protocol: ONVIF / RTSP
- Video Encoding: H.264 / H.265
- Internal Storage: 32 GB
System Integration
Interface Architecture
The XUW4008C-B combines power and network data on a single waterproof connector for straightforward vehicle wiring.
Full configuration and debug-level interface detail requires a corporate account.
Ethernet Video Interface
The camera streams H.264/H.265 video over 100Base-TX Ethernet using ONVIF and RTSP. Power and data share a single 8-pin waterproof connector rated for the camera's full depth range.
Documentation & Downloads
Public documents are available below. Additional corporate-restricted documents require a verified account. Export-controlled items require end-user certification.
2 Documents Restricted to Corporate Customers
Firmware packages, SDK archives, CAD drawings, and classified technical manuals require a verified corporate account. Apply for access and an account manager will review your registration within 1–2 business days.
Request a Quote or Demo Unit
Our technical sales team can arrange a field demonstration, provide deployment planning, and prepare a formal quotation for your procurement requirements.
Contact Sales TeamSign In to Your Account
Access restricted integration resources and downloadable documentation for verified corporate customers.
Don't have an account? Apply for corporate access →
Apply for Corporate Access
Complete the form below. Your application will be reviewed within 1–2 business days. A corporate email address is required — free webmail addresses are not accepted.
Already have an account? Sign in here →